IntelX Docs
How much new space would I gain by standing there?
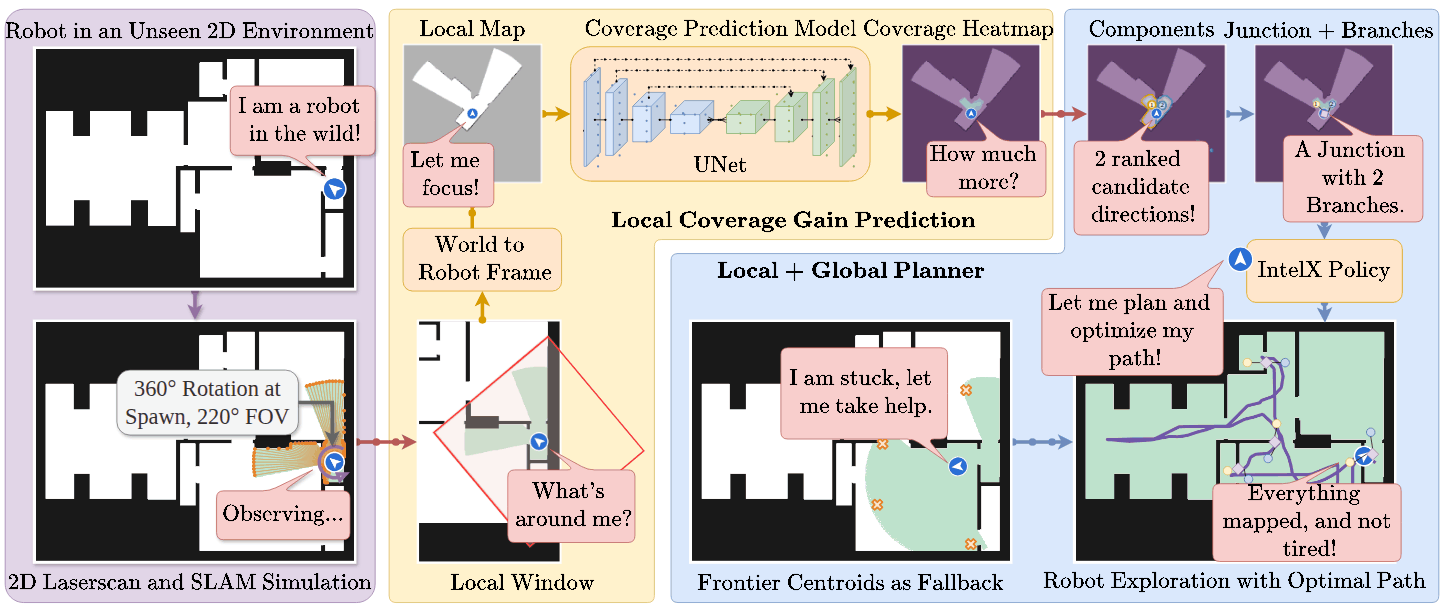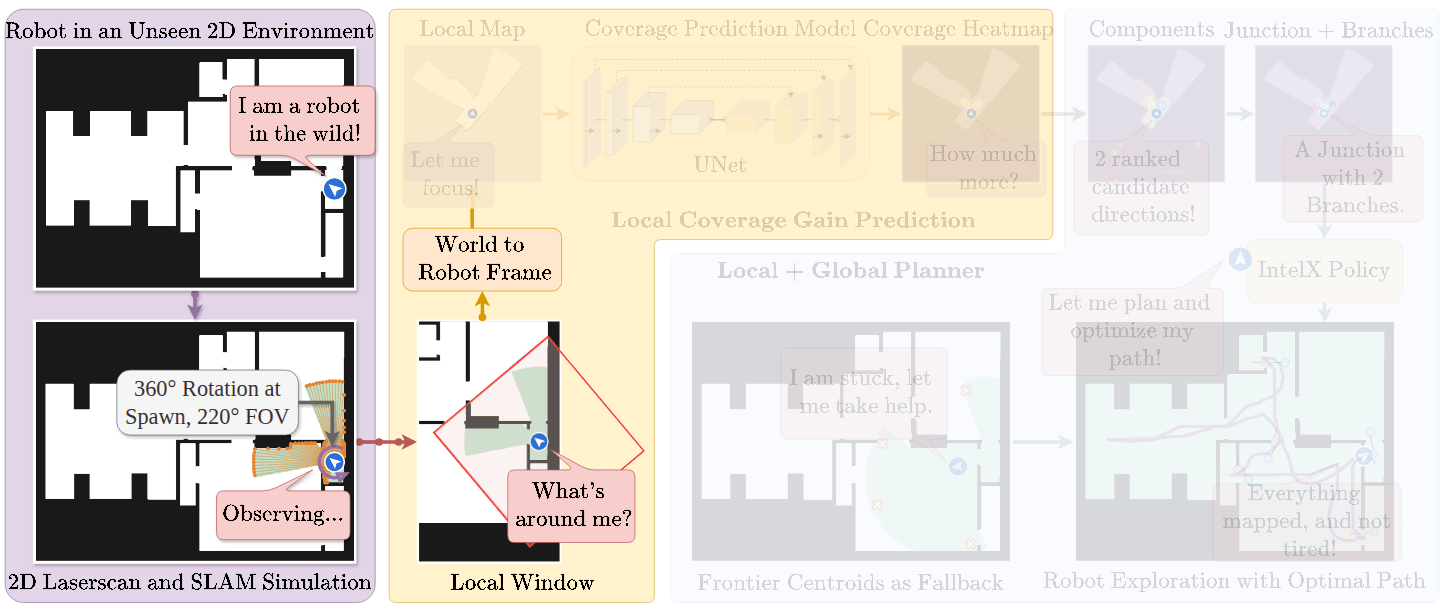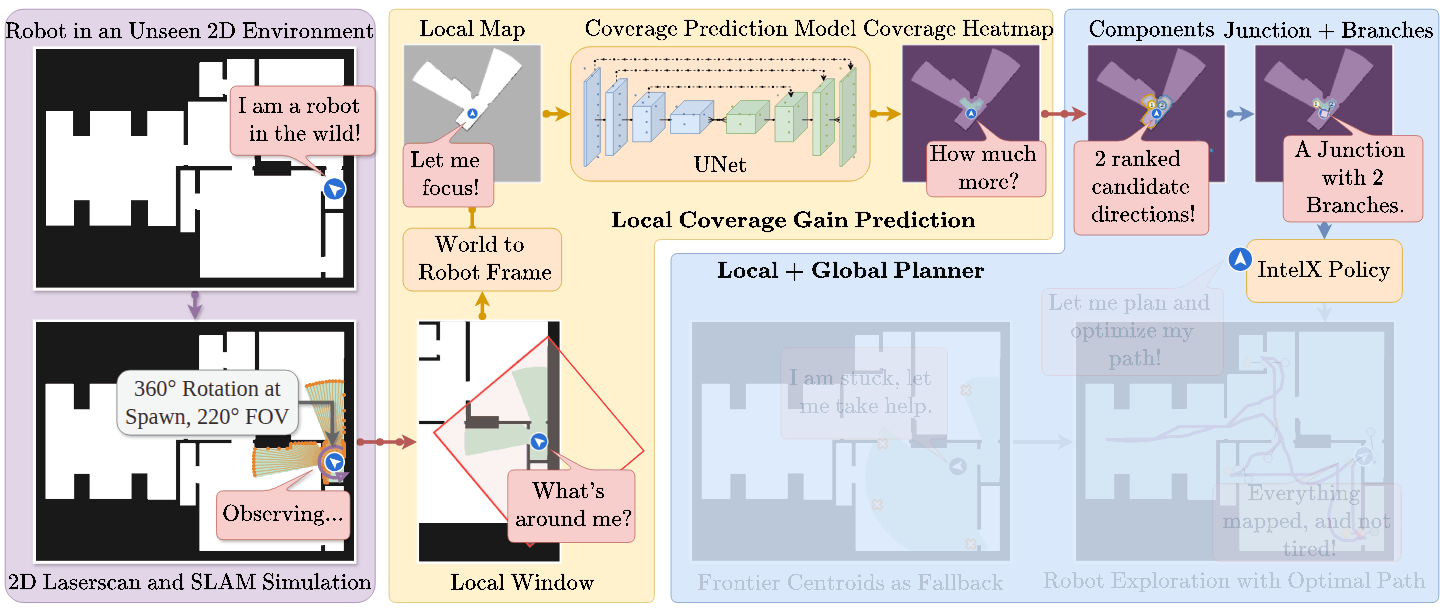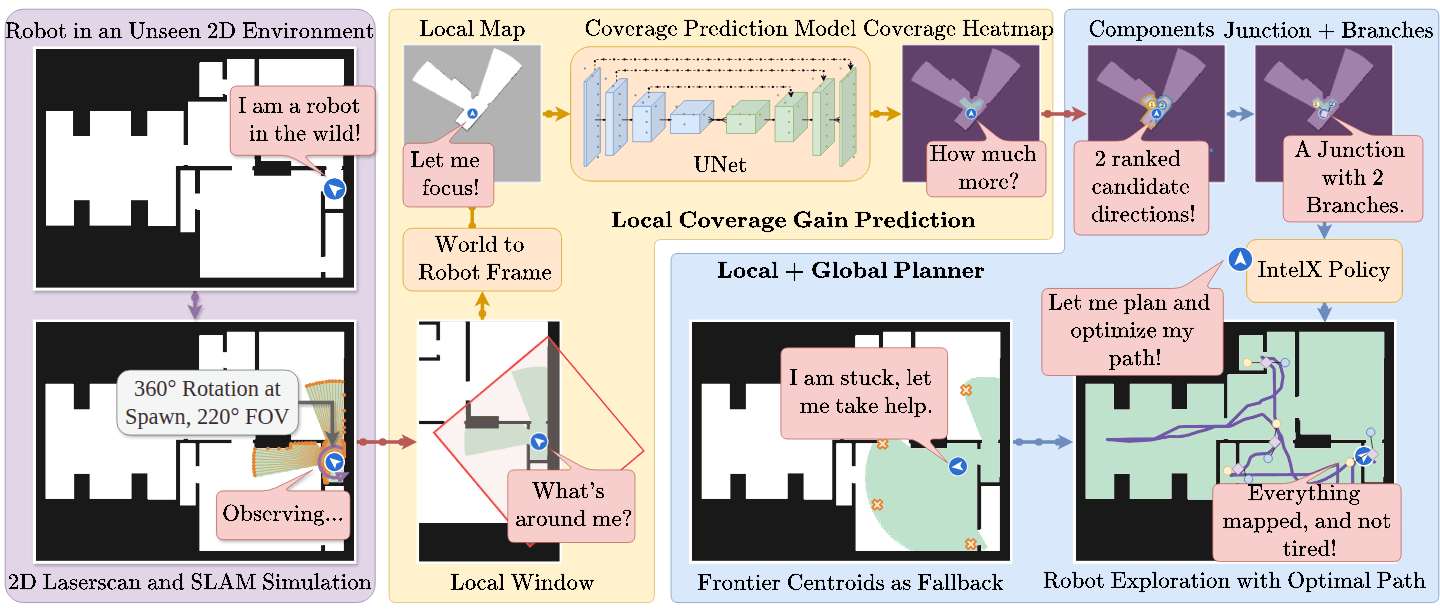
IntelX answers that question for every nearby goal with one lightweight U-Net, and explores unseen indoor spaces on the junctions it reads from the answer.
These pages cover installing IntelX, running it and every baseline in one simulator, reproducing the benchmark, and training the coverage-gain regressor.
Try It Now
git clone https://github.com/IRVLUTD/IntelX.git
cd IntelX
python3.11 -m venv .venv && . .venv/bin/activate
pip install -r requirements.txt && pip install -e .
python -m intelx.cli.run_sweep_all --selftest      # the benchmark's self-test, no GPU
The self-test runs the benchmark's own helpers, from spawn sampling and the coverage metrics to task splitting and CSV writing, with no simulator, checkpoint or GPU, so it is the fast way to check an installation. To watch IntelX explore, add the checkpoint and follow Get Started.
What the Paper Found
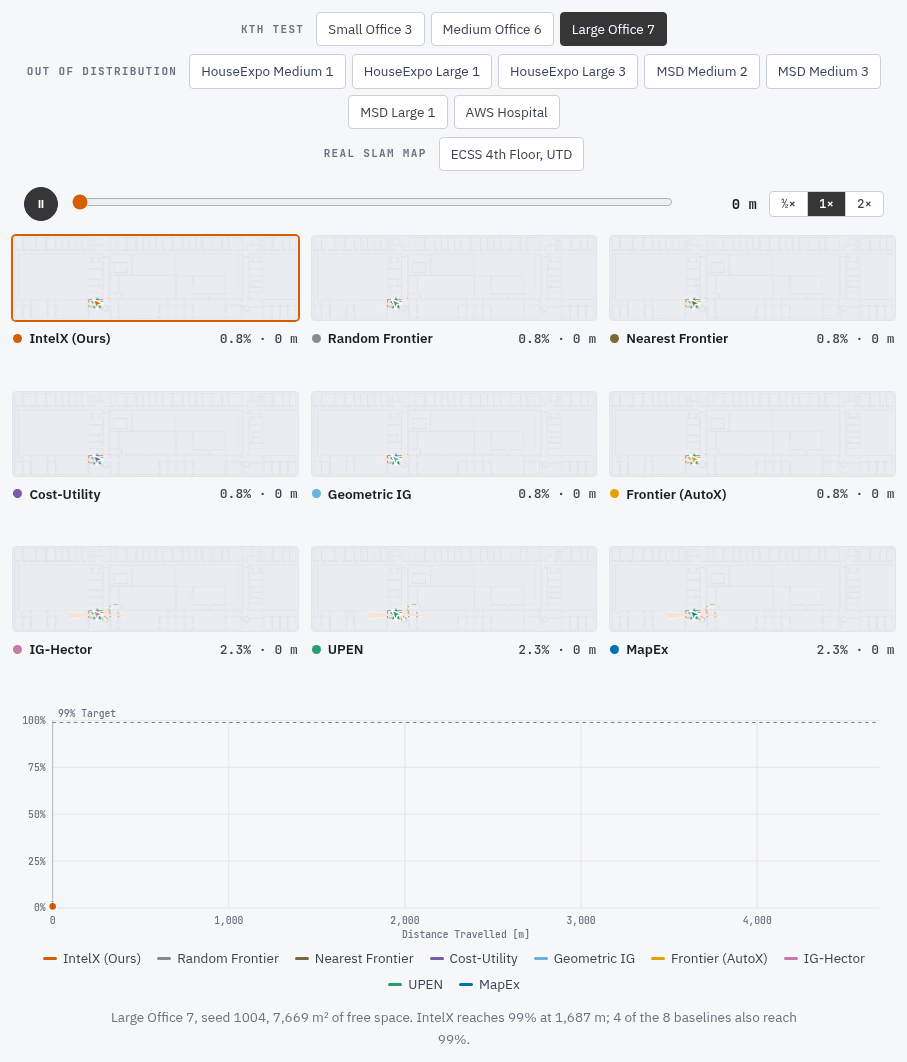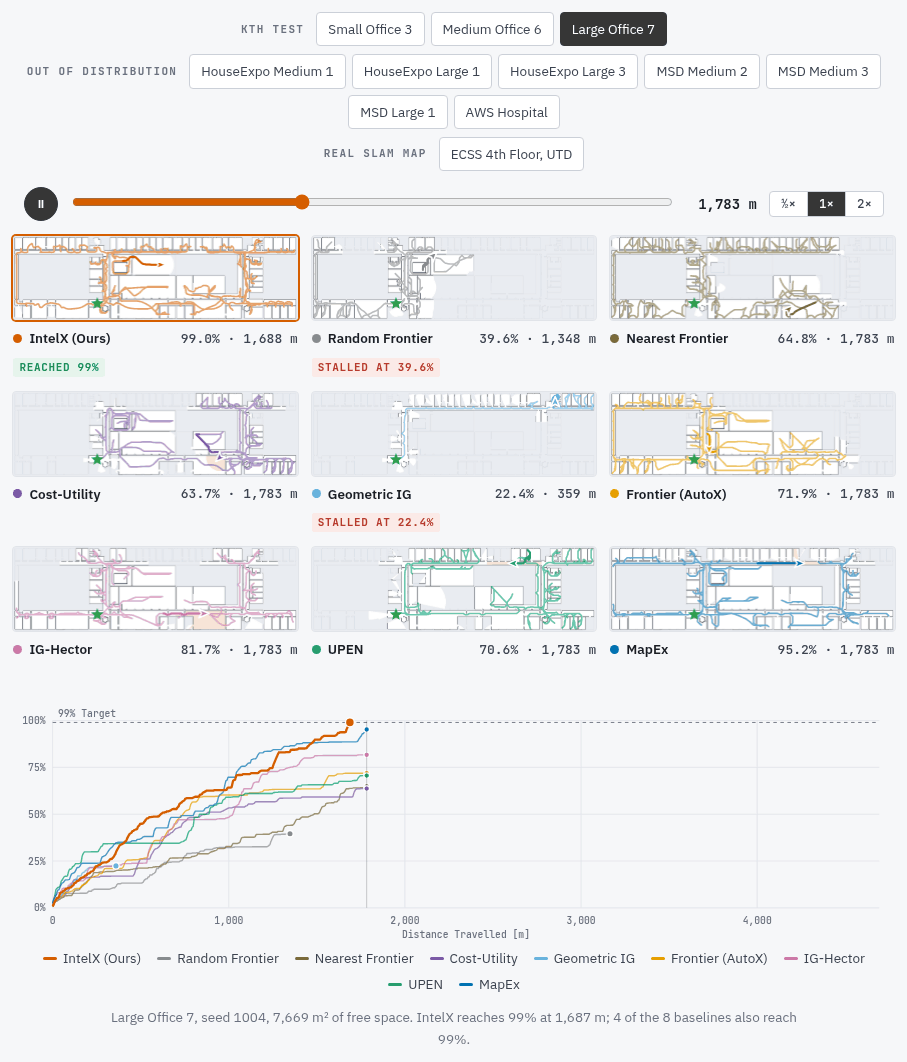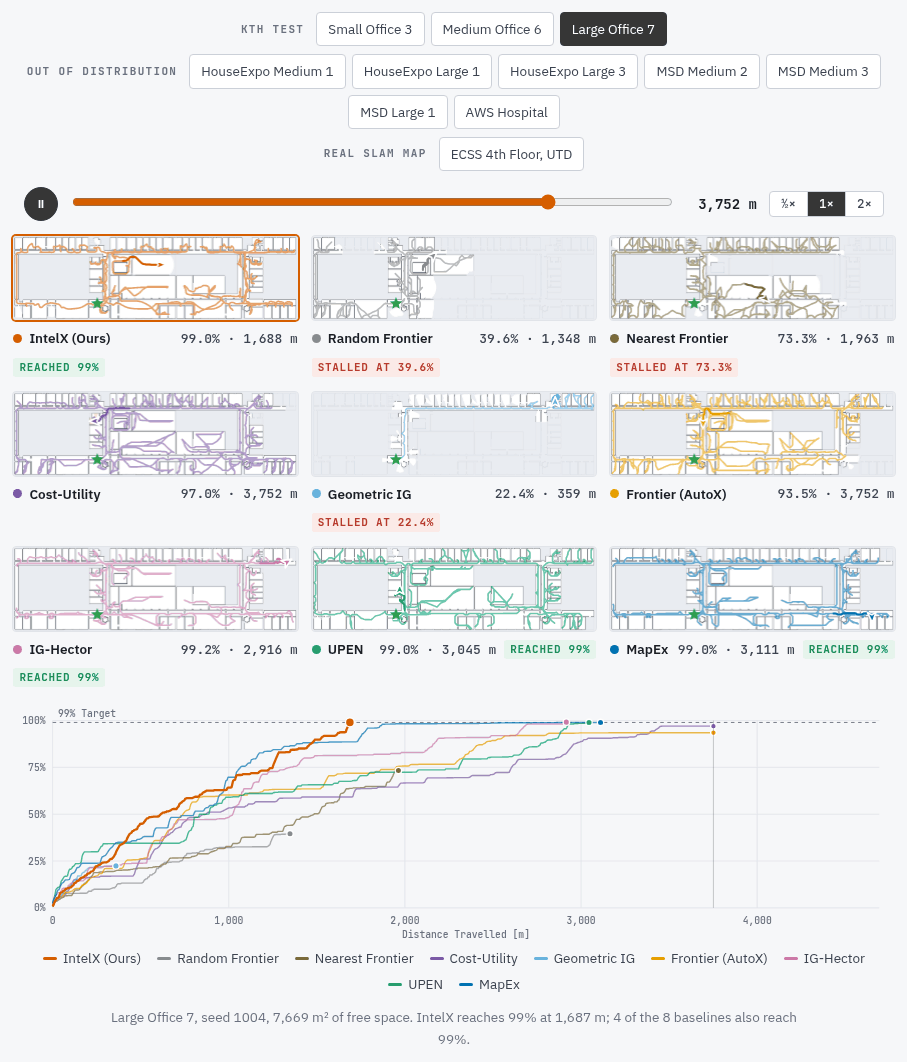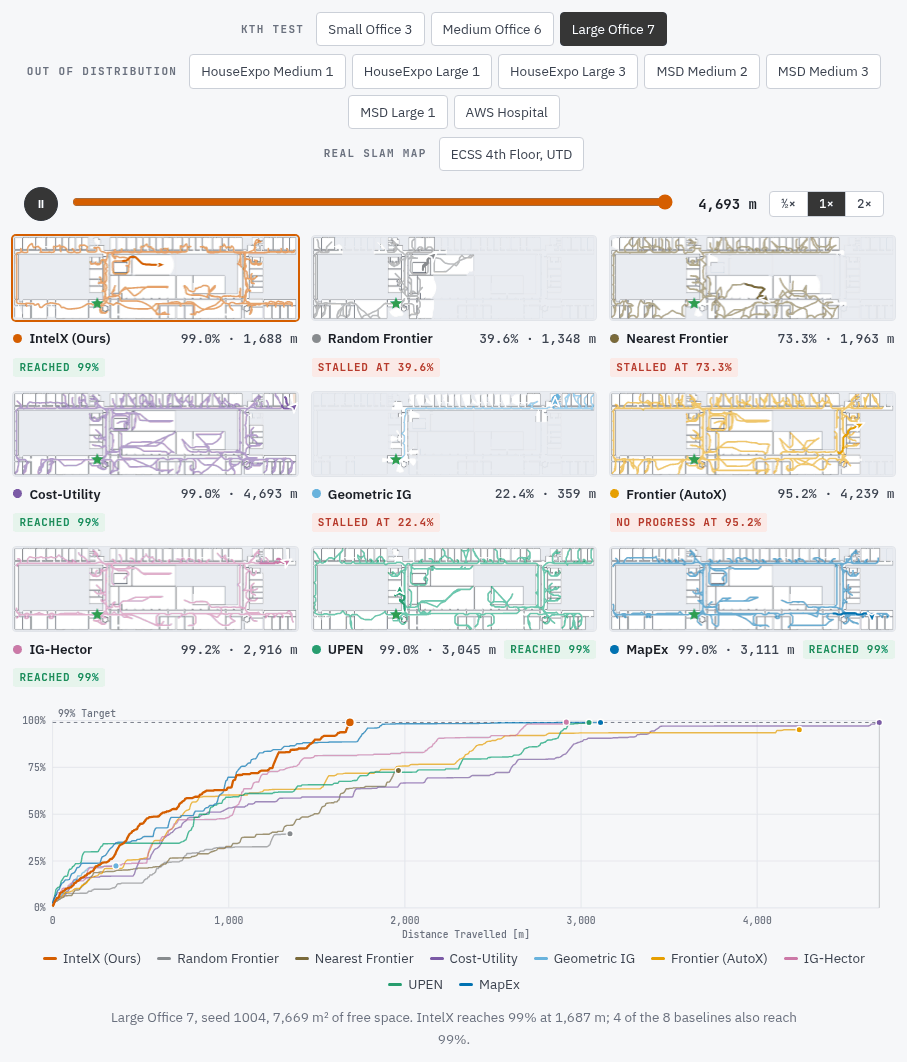
From the paper: the larger held-out maps are Medium Office 6 and Large Office 7 (Table 3), and the speed is Table 2's.
How It Fits Together
Every method runs in one 2D simulator that casts its laser rays in CUDA kernels. IntelX's regressor, a U-Net with a ResNet-34 encoder, predicts over a robot-centred 20 m window how much new area the sensor would gain from each nearby goal. The planner reads angular components of that field as candidate directions, reads multi-peaked structure as a junction, and commits to branches weakest first. The global planner keeps each junction's branches and, when the window offers nothing, heads for the nearest active branch or frontier. The benchmark draws one spawn per map and seed and runs every method from it.
| Key | Method | Notes |
|---|---|---|
ours |
IntelX | the coverage-gain field, the local and the global planner |
local_only |
IntelX, Local Only | the ablation without the global planner |
random nearest cost_utility geom_ig |
Random Frontier, Nearest Frontier, Cost-Utility, Geometric IG | geometry only |
frontier |
Frontier (AutoX) | our previous work, a dynamic-window frontier explorer |
mapex upen hectoraug |
MapEx, UPEN, IG-Hector | need MapEx and its service |